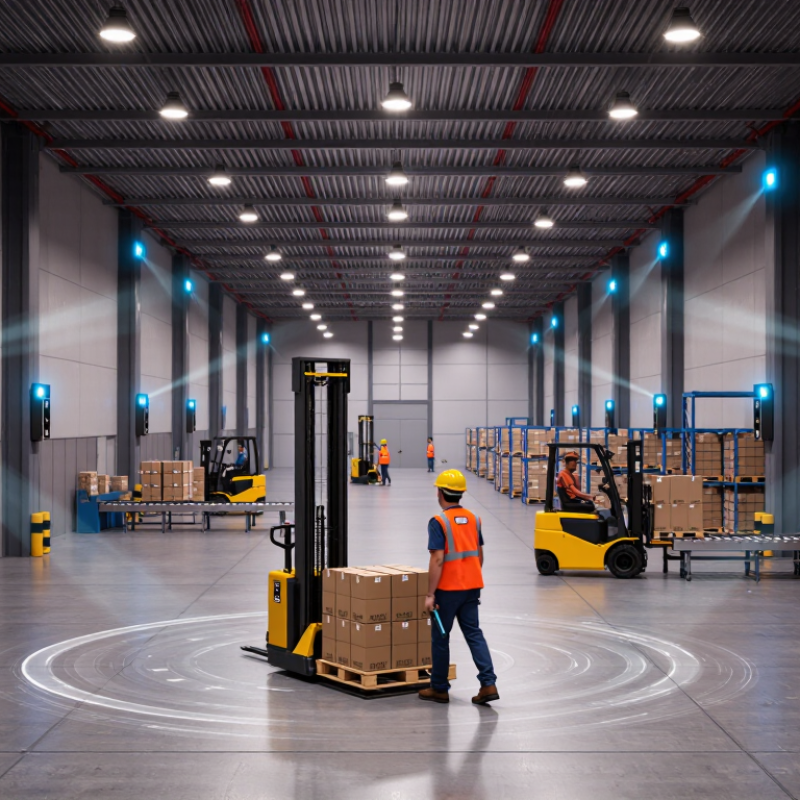
Ultra Wideband Positioning uses very short radio pulses to estimate distance between devices with remarkable precision. Unlike conventional wireless systems, it measures signal travel time rather than relying mainly on signal strength. A small tag may be attached to a worker’s helmet, pallet, vehicle, or tool. Fixed anchors listen for the tag’s transmission and calculate its location through time of flight. With multiple anchors, the system can produce a live position on a site map.
The principle sounds simple. The installation is not.
A warehouse may need carefully measured anchor locations, synchronized equipment, and reliable calibration. Metal racks, concrete walls, moving machinery, and crowded radio environments can reflect signals. These reflections may create small errors or unstable readings. Ultra Wideband Positioning can often reach decimeter-level accuracy in suitable conditions, but real performance depends on hardware, layout, firmware, and environmental testing. Claims of guaranteed centimeter accuracy deserve careful review.
Technologies such as two-way ranging and time difference of arrival support different deployment models. Each approach affects cost, scalability, power consumption, and maintenance. Security also matters, because location data can reveal sensitive operational patterns. Modern standards, including IEEE 802.15.4z, help strengthen ranging reliability and resistance to certain attacks. Yet standards do not replace responsible system design.
This guide examines how the technology works, where it performs well, and where it struggles. It also questions easy promises. Positioning is not magic. Good results come from measurement, testing, and honest limits.
Ultra Wideband positioning uses radio signals to estimate the distance between a moving tag and fixed reference points. Its defining feature is a broad frequency range, commonly described as 3.1–10.6 GHz. In many regulatory definitions, the signal occupies at least 500 MHz of bandwidth. This wide span allows very short signal pulses, creating fine time resolution for location measurement.
The system measures how long a pulse takes to travel between devices. Multiplying that travel time by the speed of light gives an estimated distance. Several fixed anchors then compare distances and calculate the tag’s position, often within rooms, warehouses, or industrial areas. In field testing, centimeter-level results are possible under good conditions. Synchronization, antenna placement, and calibration still matter greatly.
Wide bandwidth does not guarantee perfect accuracy. Walls, metal racks, people, and reflective surfaces can distort the first arriving signal. A clean laboratory layout may hide these problems. That model is useful, but incomplete. Practical deployments need repeated measurements, careful anchor geometry, and checks against known reference points. Even then, motion, blocked paths, and regional spectrum rules can reduce performance. A 500 MHz channel provides strong timing detail, yet software must interpret noisy reflections correctly. Small installation errors can become visible when a device moves near a corner.
Ultra Wideband positioning uses short radio pulses to estimate distance with exceptional timing precision. Its practical core is a small network of anchors, mobile tags, and IEEE 802.15.4z UWB radios.
Anchors are fixed reference points mounted around a room, warehouse, or work area. Their surveyed coordinates create the positioning frame.
A tag is attached to a person, tool, or vehicle. It exchanges timed messages with several anchors. The system then calculates distances from signal travel time.
Two-way ranging measures the round-trip delay between a tag and an anchor. Time-difference methods compare when signals reach separate anchors.
IEEE 802.15.4z improves ranging reliability through better timestamping and stronger protection against manipulated measurements. It does not remove every error. Walls, metal shelves, and blocked paths can still create non-line-of-sight delays.
Tips: Place anchors high and apart, then verify their coordinates carefully. Keep antennas clear of metal. Test real movement patterns, not only open-room conditions. Use more anchors when coverage matters more than hardware savings.
In field testing, calibration often matters as much as radio capability. A misplaced anchor can shift every tag position. That is easy to miss. Temperature, mounting surfaces, and firmware timing may also influence results. A reliable installation records these conditions and checks accuracy repeatedly, because a clean laboratory result may not survive daily movement.
What Is Ultra Wideband Positioning and How Does It Work?
Ultra Wideband positioning estimates distance by measuring a radio pulse’s time of flight. The signal travels to a device, reflects or returns, and reaches the receiver. Distance equals travel time multiplied by radio-wave speed, then divided by two for a round trip. A one-nanosecond error represents roughly 15 centimeters of distance. That explains the engineering challenge.
IEEE 802.15.4z improves ranging reliability through stronger timestamp security and better measurement methods. The European Telecommunications Standards Institute describes UWB as operating across very wide frequency bandwidths, supporting fine time resolution. Industry testing commonly reports accuracy near 10 centimeters in controlled environments, while walls, metal, body absorption, and poor clock alignment reduce performance. A 2023 report from the GSMA Intelligence research team identifies precise indoor positioning as a major use case for UWB, especially in logistics and industrial automation. Real sites are less tidy, though. Ten centimeters is not guaranteed.
Tips: Install several fixed anchors around the area, not in one corner. Keep antennas away from large metal surfaces. Measure performance with moving people, open doors, and temporary obstacles. Record error ranges, not only the best result. Calibration matters more than impressive laboratory numbers. A practical deployment should also compare time-of-flight readings with inertial or map data. That extra layer can catch sudden jumps, but it adds complexity and maintenance. Test before scaling.
Ultra Wideband positioning estimates a device’s location by measuring radio signal travel time. The method depends heavily on location algorithms, not only on accurate hardware.
Trilateration uses distances from a tag to at least three known anchors. Each distance forms a circle, and their intersection estimates the tag’s position. In practice, walls and reflected signals shift these circles.
TDoA uses differences in arrival time instead of direct distance measurements. Synchronized anchors compare when the same signal reaches them, then calculate a position from those time differences. This approach can reduce tag-side complexity, but clock drift still creates errors.
Anchor geometry matters too. Wide, well-spaced anchors usually produce stronger results than clustered ones. Poor geometry amplifies small timing mistakes.
Small errors matter. A warehouse test may look excellent, while a metal-lined corridor performs poorly. I would not treat one successful trial as proof of reliability.
Tips: Place anchors around the working area, not in one corner. Keep clear sight lines where possible, and document anchor height and coordinates. Measure known reference points before daily operation. Check for non-line-of-sight conditions, clock instability, and sudden position jumps. A confidence score should accompany every location result. Review failed readings, rather than quietly deleting them. That habit often reveals installation problems that the algorithm cannot fix.
Ultra-wideband (UWB) positioning estimates distance by measuring how long brief radio pulses take to travel between a tag and fixed anchors. Its wide spectrum supports fine timing, often enabling 10–30 cm tracking in well-designed indoor environments. The system calculates several distances, then intersects them to estimate the tag’s location. Timing quality matters. A small clock error can shift the reported position.
Line of sight gives the cleanest result because the signal follows a direct path. Walls, shelving, people, and metal surfaces create multipath, where copies of the pulse arrive at different times. A receiver may then choose a reflected path and place a moving cart beside its real position. Algorithms can reject suspicious measurements, but they cannot repair every bad installation. Anchor height, spacing, antenna orientation, and calibration deserve practical testing.
This makes UWB useful for indoor equipment tracking, worker-location alerts, robotic navigation, and room-level interaction. Yet 10–30 cm should be treated as a measured range, not a permanent guarantee. Dense rooms can reduce reliability. Body blocking may cause brief jumps. The environment wins. A careful deployment logs errors at doors, corners, and crowded aisles, then adjusts anchor geometry. That extra testing is easy to underestimate. It is also where many accuracy claims become less convincing.
Ultra-wideband positioning estimates location by measuring how long radio signals travel. It turns timing into distance. Accuracy near ten centimeters is possible in controlled environments.
The system measures a signal’s round-trip travel time. It multiplies time by radio-wave speed, then divides by two. A one-nanosecond error can create roughly fifteen centimeters of distance error.
Walls, metal surfaces, people, and absorbed signals can weaken results. Poor clock alignment also creates timing mistakes. Ten centimeters is not guaranteed.
Trilateration normally needs at least three known anchors. More anchors can improve coverage and reliability. Place them around the working area, not in one corner.
Trilateration uses distances from a tag to several fixed anchors. Each distance creates a circle around an anchor. Their intersection estimates the tag’s position.
TDoA compares when the same signal reaches synchronized anchors. The system uses arrival-time differences to calculate location. Clock drift can still cause errors.
Keep antennas away from large metal surfaces. Use wide spacing and clear sight lines when possible. Record each anchor’s height and exact coordinates.
Test moving people, open doors, and temporary obstacles. Measure known reference points before daily operation. Record error ranges, not only the best results.
Inertial or map data can help identify sudden position jumps. This added layer increases complexity and maintenance. It is useful, but not flawless.
Do not treat one successful warehouse trial as proof of reliability. Review failed readings instead of deleting them quietly. Some errors reveal installation problems, not algorithm failures.
Ultra Wideband Positioning is a high-precision location technology that uses very short radio pulses across a broad 3.1–10.6 GHz spectrum, with bandwidths of at least 500 MHz. Its system typically includes fixed anchors, mobile tags, and UWB radios designed around the IEEE 802.15.4z standard. By measuring the time required for a signal to travel between devices, the system can estimate distance with accuracy approaching 10 centimeters under suitable conditions.
After collecting distance or timing data, positioning algorithms calculate the tag’s location through methods such as trilateration and time difference of arrival (TDoA). Accuracy depends greatly on anchor placement, line of sight, and the surrounding environment. Reflections and multipath signals from walls, machinery, or other objects can reduce performance, while well-planned anchor geometry improves reliability. In practical deployments, Ultra Wideband Positioning can support tracking accuracy of roughly 10–30 centimeters for people, equipment, and other authorized assets.
| Data Dimension | What It Means | Typical UWB Positioning Characteristics | Effect on Accuracy | Practical Uses |
|---|---|---|---|---|
| Positioning Principle | UWB positioning estimates the distance or relative position between radio devices by measuring the travel time of very short radio signals. | Common methods include two-way time of flight, time difference of arrival, and angle-assisted ranging. | Time-based measurement can provide precise ranging because radio signals travel at a known, nearly constant speed. | Indoor asset tracking, worker-location monitoring, robot navigation, access systems, and interactive spaces. |
| Signal Bandwidth | Ultra wideband uses radio signals with very wide bandwidth and short-duration pulses or pulse-like waveforms. | Regulatory frequency limits vary by region; many UWB systems operate across several gigahertz of spectrum. | Wide bandwidth helps distinguish the direct signal from delayed reflections, improving resistance to multipath errors. | High-precision ranging in warehouses, factories, hospitals, offices, and other dense indoor environments. |
| Typical Accuracy | Accuracy describes the difference between the reported position and the actual physical position. | Approximately 10–30 cm is achievable in well-designed systems with suitable anchor placement and favorable radio conditions. | Real-world accuracy can be lower because of non-line-of-sight paths, poor geometry, interference, calibration errors, and moving objects. | Zone-level tracking, precise equipment location, automated inventory, and proximity-based control. |
| Line of Sight (LOS) | LOS exists when the direct radio path between a mobile device and a reference anchor is unobstructed or only lightly obstructed. | LOS normally provides the most stable time-of-flight measurement and the lowest ranging bias. | Best conditions for reaching roughly 10–30 cm tracking performance, depending on system design. | Open warehouses, production floors, corridors, sports areas, and outdoor sites with clear paths. |
| Non-Line of Sight (NLOS) | NLOS occurs when walls, machinery, people, vehicles, or other objects block the direct path. | The receiver may measure a reflected or delayed path instead of the shortest direct path. |
"*" indicates required fields